fixtures and CAD
- My contribution
- I personally design and 3D print all mounts, adapters, and fixtures used on the lab's Epson robots, on the lab's Bambu Lab and Form 3 printers.
- Tool-changer retrofit
- We bought Destaco RHC-2-T quick-change tool changers used on eBay and needed an adapter to the C4's force-sensing end-effector flange. Nothing off the shelf fits it, so I designed and printed one.
- Workcell fixtures
- Camera mount and Seyonic pipette mount on the VT6-A901S workcell, and a gripper adapter on the FAST plate assembly robot.
- BSL2 clamp
- A linear-actuator holder that rides rails to clamp biosensor chips at roughly 10 kg of force.
I design and 3D print every mount, adapter, and fixture on the lab’s robots myself, in Autodesk Fusion 360, and print them in-house on a Bambu Lab and a Formlabs Form 3. The six parts below are my STEP exports rendered for the web; drag to rotate, scroll to zoom.
Tool-changer adapter
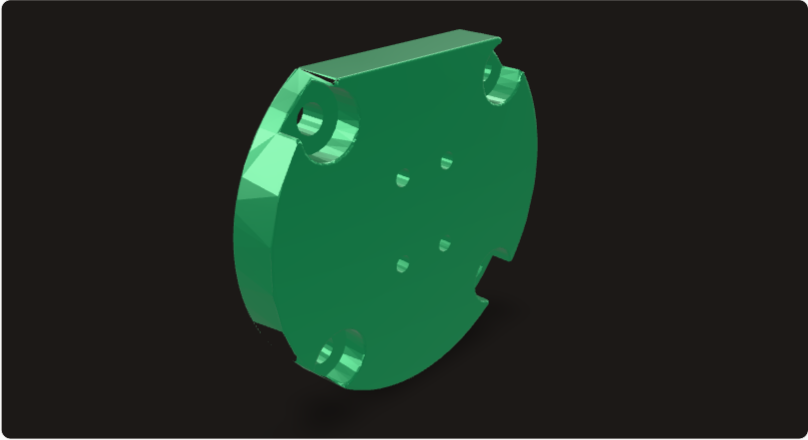
The C4 workcell swaps tools through a Destaco RHC-2-T quick-change tool changer, bought used on eBay. Destaco publishes the changer’s tooling pattern but nothing mates it to the Epson’s force-sensing flange, so I measured the flange, designed this adapter, and printed it. It sets the repeatable registration every tool change relies on.
Tool-changer holder
The bench cradle the tool rests in between operations. The fork keeps a parked tool presented at a fixed pose so the arm can find it the same way every cycle.
Gripper adapter
The assembly robot grips FAST plates through this adapter. It couples the gripper to the arm’s mounting pattern while keeping the sensor’s approach clearances intact.
Camera mount
The camera on the VT6-A901S workcell runs on this bracket. Its stiffness and fixed pose are what let the vision step trust pixel-to-millimeter conversions.
Pipette mount
The Seyonic electronic pipette lives on the VT6-A901S arm in this housing. It carries the pipette rigid enough for the liquid-level detection descent modes to stay accurate across the deck.
Linear actuator holder
In the BSL2 lab, biosensor chips need about 10 kg of clamping force during a functionalization step. This holder carries a linear actuator on rails so the clamp comes down square onto the chip, every run.
The library is larger than these six. These are the parts that survived contact with the bench: measured in CAD, printed in-house, installed on the robots, and maintained since.